
Motion Capture
Based Humanoid
Robot Training System
An integrated learning data platform that safely and accurately transfers human movements to humanoid robots based on high-precision motion capture.
XERO Humanoid synchronizes and collects human motion and video data, Retargets them according to the robot structure, and provides them as a dataset that meets the specifications of the supported simulation and learning environment.
XERO Humanoid integrates the entire policy learning process into a four-stage pipeline.
STEP 01
Data Collection
We collect high precision motion data based on motion capture.
• Motion capture + First-person video
• VR mode
• Teleoperation
• Real-time URDF retargeting
• Session management by episode and take
STEP 02
Export
We are proceeding with casting conversion and retargeting.
• BVH/Motion Capture → URDF mapping
• Support for 6 output formats
• Automated batch processing
• XERO ReTarget pipeline
STEP 03
Simulator Verification
Thoroughly verify robot behavior in Isaac Lab and MuJoCo environments.
• Joint limit and self-collision checks
• Grounding and continuity quality assessment
• Step-by-step quality reports
• Integration with external learning frameworks
STEP 04
Robot Deployment
It is securely applied to a proven, real-world security platform during the session.
• Step-by-step application through safety gates
• Recording point setting snapshot inheritance
• Session-level history and deliverable receipts
• Reproduction under identical conditions
ONE CONTINUOUS PIPELINE
From Data to Robot Motion
Multi Sensor Fusion
It fuses data from various tracking devices—such as XEROmotion, Xsens MVN, and VIVE Ultimate Tracker into a single stream.
Realtime Retargeting
It converts optical, IMU, and hybrid inputs into a URDF-based robot skeleton in real time.
NVIDIA Native Integration
It connects directly to Isaac Sim, Isaac Lab, GR00T-Mimic, and the NVIDIA Teleop API.
Standard format compatible
It supports HDF5, MP4, CSV, BVH, and LeRobot dataset formats.
Training-Ready
It provides raw motion data, video, sensor data, action labels, physical information, and metadata in a consistent structure.
End-to-End
Everything from data preparation, training, and simulation-based validation to actual robot deployment is completed within a single environment.
XERO Humanoid integrates data collection, retargeting, AI training, validation, and real-world robot deployment into a single pipeline. It bridges the gap between disparate sensors and simulators, delivering data that is ready for immediate training.
THREE CAPTURE MODES
Data collection tailored to the purpose

MoCap + Video
It hardware-synchronizes optical or IMU motion capture with first-person view video with a latency of less than 1 ms.
-
Full-body 3D joint trajectories
-
Simultaneous recording of first-person video
-
GR00T-Mimic data generation

VR
Run VIVE UT and HMD-based actions in real-time within Isaac Sim and generate large-scale synthetic data.
-
Robot's first-person perspective (integrated with Isaac Sim)
-
Full-body motion-based control
-
Continuous recording, including failures and retries
-
Safe demonstration of hazardous tasks

Teleoperation
Pass the XERO Mocap fusion output to the NVIDIA Teleop API and simultaneously record the trajectories of both the human and the robot.
-
Robot Joint Commands
-
Precise Measurement of Execution Trajectories
-
High-Faith Real-Environment Data

It links diverse data such as full body movements, hand actions, objects, and video footage based on a common timeline.
By maintaining the correspondence between task contexts and movements, it enables the collected data to be consistently utilized for analysis and learning.
TRAINING-READY DATA
Consistent Data Structure, Ready for Immediate Training
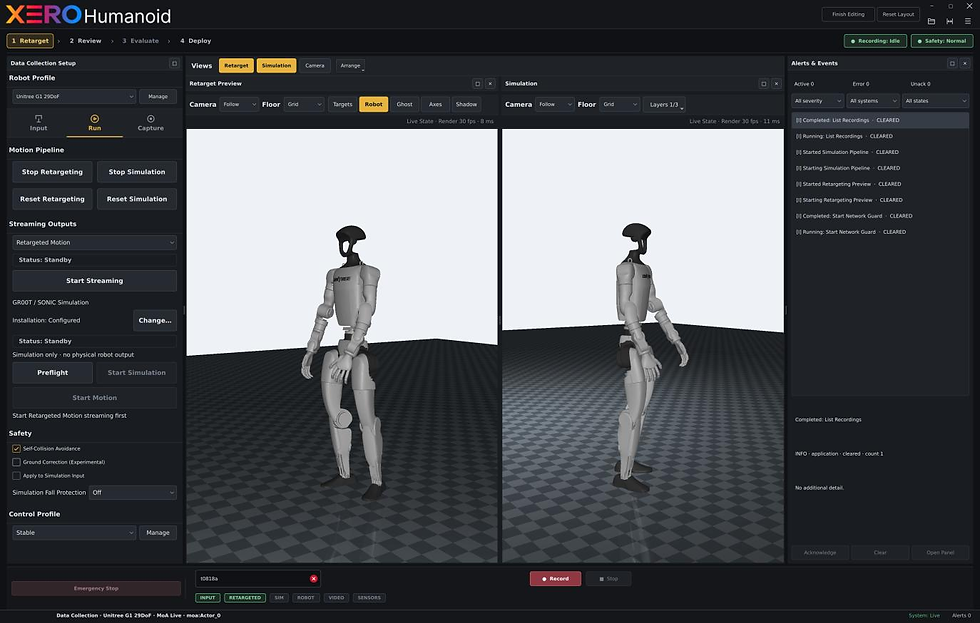
UNIFIED DATA POLICY
A single Timeline.
A single Standard.
It synchronizes vision, physical movements, sensors, and physical data, providing a consistent structure that robots and simulators can use immediately.
Master Training Data
HDF5
Synchronized RGB Video
MP4
Metadata & Calibration
Isaac Sim & MuJoCo
JSON / YAML
USD
It organizes synchronized motion and video data along with task information into a consistent structure and outputs the data in a format that meets the specifications of the target learning environment. This reduces the need for repetitive data organization and format conversion tasks following data collection.
HDF5
Master data · robomimic standard and GR00T-Mimic field compatible
MP4
Synchronized RGB and first-person video
JSON /
YAML
Metadata and Calibration
USD
NVIDIA Isaac Sim Simulation
MJCF /
XML
Add paragraph text. Click “Edit Text” to update the font, size and more. To change and reuse text themes, go to Site Styles.
Training- Ready Package
-
Raw motion and full-body 3D joint trajectories
-
Synchronized first-person and observer camera footage
-
Raw and fused multi-sensor data
-
Action labels and sub-task signals
-
URDF-based robot retargeting data
-
Physical data (contact, force, velocity, etc.)
-
Calibration and session metadata
Training-Ready Data
MJCF /
XML
MuJoCo Models and Environments
NATIVE ECOSYSTEM
It connects seamlessly with the Physical AI ecosystem.
Add paragraph text. Click “Edit Text” to update the font, size and more. To change and reuse text themes, go to Site Styles.
Isaac Sim
SIMULATION
Isaac Lab
ROBOT LEARNING
GR00T / SONIC
POLICY RUNTIME
MuJoCo
PHYSICS ENGINE
ROS 2
ROBOT MIDDLEWARE
robomimic
HDF5 STANDARD
URDF
ROBOT MODEL
NVIDIA Teleop
REAL ROBOT CONTROL
Efficiency That Speaks for Itself
This is the space to introduce the Services section. Briefly describe the types of services offered and highlight any special benefits or features.
User-Friendly Interface
Describe the service and how customers or clients can benefit from it.
24/7
Support
Describe the service and how customers or clients can benefit from it.
Cost-Effective Solutions
Describe the service and how customers or clients can benefit from it.
Scalable
and Flexible
Describe the service and how customers or clients can benefit from it.
Extensive hardware integration
Build the optimal hardware environment for your needs—from optics, IMUs, and VR trackers to haptic gloves.

XEROmotion
XEROmotion captures precise human and object movements through optical tracking, providing motion data for robot training and imitation learning.
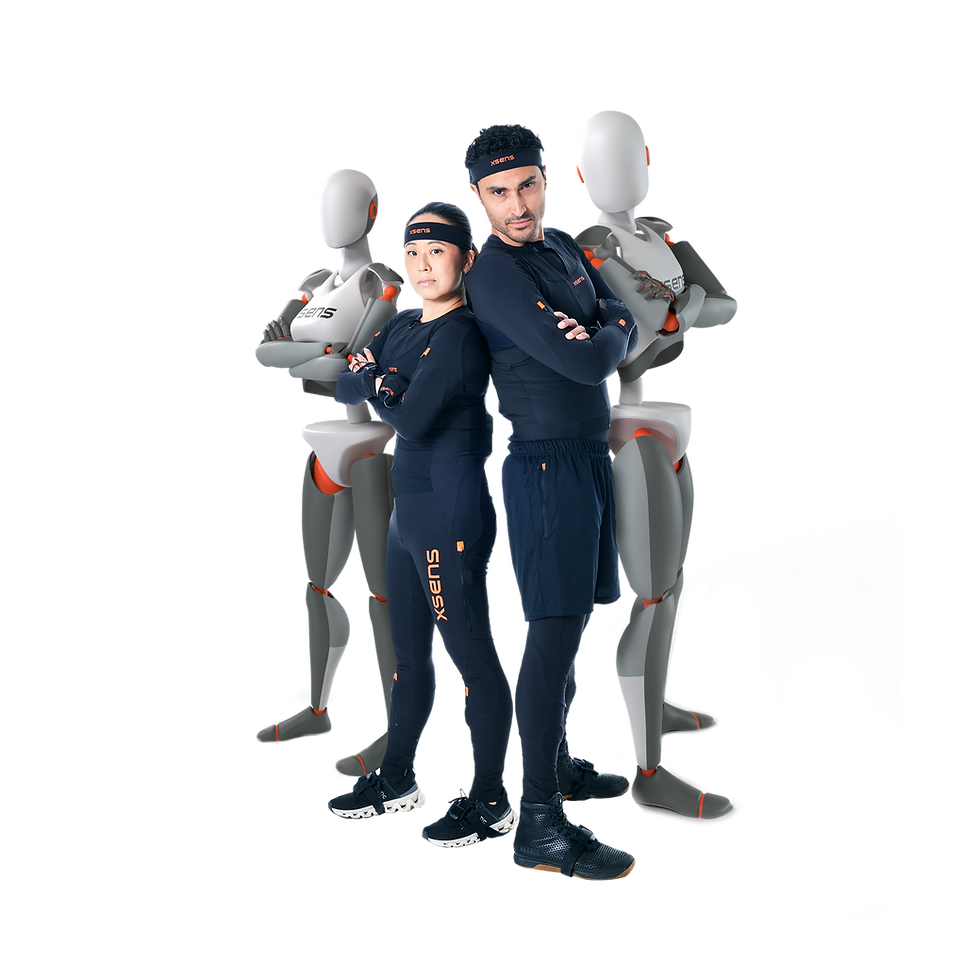
Xsens MVN
Xsens MVN captures full-body motion without external cameras, simplifying data collection for humanoid robot imitation learning.

VIVE Ultimate Tracker
VIVE Ultimate Tracker captures body movements without external base stations, supporting motion data collection for robot training.
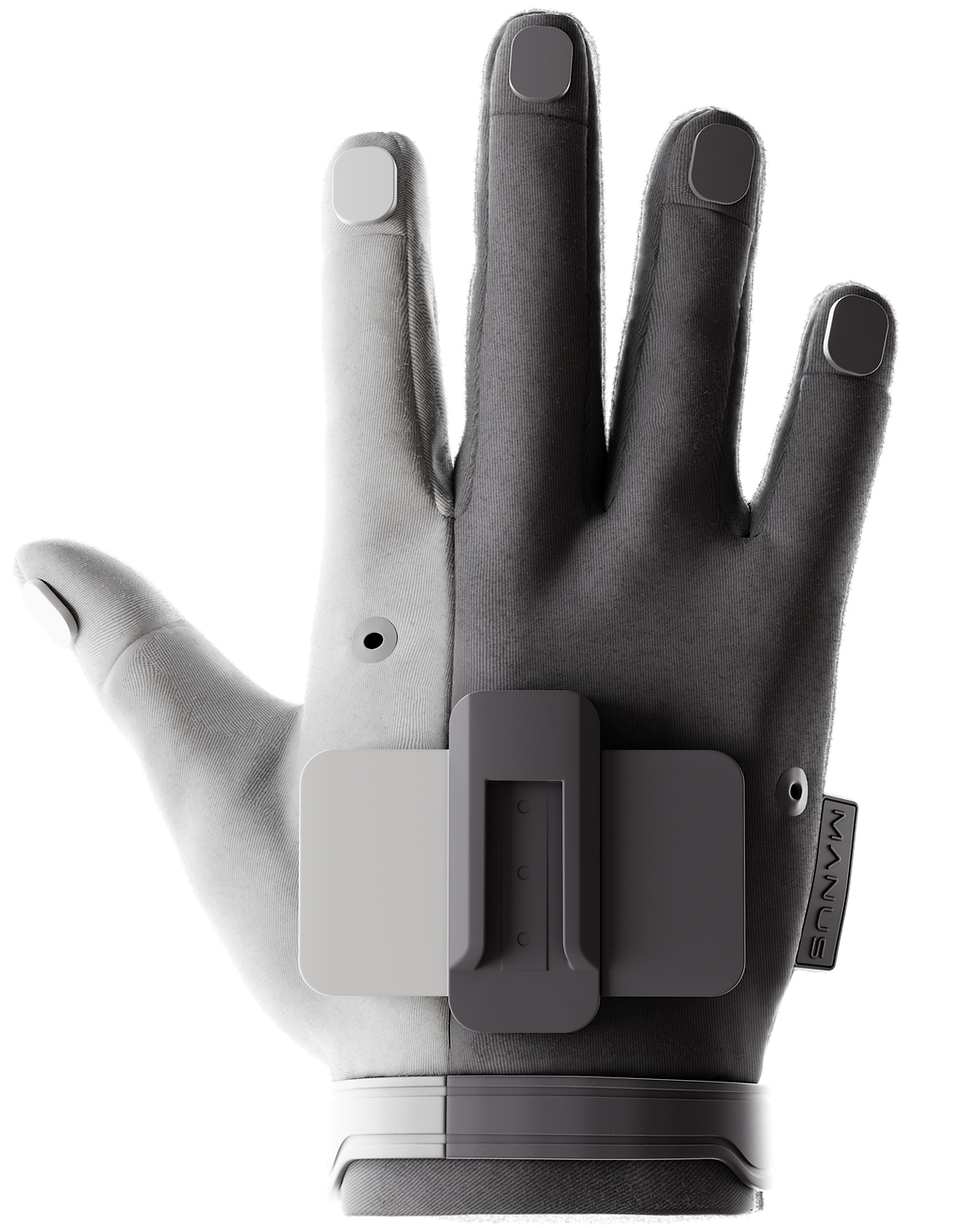
MANUS Glove
MANUS Gloves capture precise hand and finger movements, simplifying data collection for robotic manipulation and imitation learning.
Video of the XERO Humanoid
If the goal is deployment in actual industrial settings, motion capture-based systems offer advantages in every aspect, ranging from data precision to safety.


PURE MOTION, ZERO ARTIFACT
Transform the starting point of humanoid training data.
Capture, learn, and validate human motions using the XERO Humanoid, and deploy them to a real robot.